Huh,
Atlassian Jira functionality has moved again. Now Claude and Cursor are my teammates! Do they get the job over Rovo...? Let's see... ;-)
TL;DR
New features for handling tracks, direct integration with the Jira issue (work item), context retrieval from the D3.js visual for any viewer of the Jira issue.
Remember the North Star…?
“Can we capture a visual selection on an asset and attach it to a Jira work item in such a way that another engineer could re-open later?”
The previous post (see here) validated our idea. Sticking with our architecture bets (constraints), if you recall:
- Qualifies for **Runs on Atlassian**
- Multiple entry points for the **Track Linker** app are assumed (globalPage, issueAction, Rovo?)
- UI Kit <-> Frame two-way communication continues to be a growing contract, deepening context
What Do Later Phases Give Us?
Phases 1-6 offer infrastructure maturity and narrow down most workflow steps needed to make this REAL operationally.
Not super-catchy I know, but I can't vouch that all steps in solution design are...
| Phase (Tag) |
Milestone |
Description |
| 0 (v0.0.0) |
|
Detailed post. |
| 1 (v0.0.1) |
(App) Entry-aware shells (global vs issue)
|
Splitting codebase contexts before piling features on one screen |
| 2 (v0.0.2) |
ADS tokens; map controls in UI Kit |
Starting to make it look like an Atlassian app |
| 3 (v0.0.3) |
|
Choose your circuit |
| 4 (v0.0.4) |
Arc-length geometry |
D3 - translate visual co-ordinates to meaningful physical distances |
| 5 (v0.0.5) |
Link to current issue + restore
|
Integration to existing / current work item (not just new ones) |
| 6 (v0.0.6) |
App custom fields on issue view
|
Integration of track segment data onto the issue.
Might be achieved with labels and components (?).
|
Deeper UI Kit <-> Frame Context
With each phase a growing contract between the UI Kit and Frame components tightens the integration and makes those interactions (events) more informative.
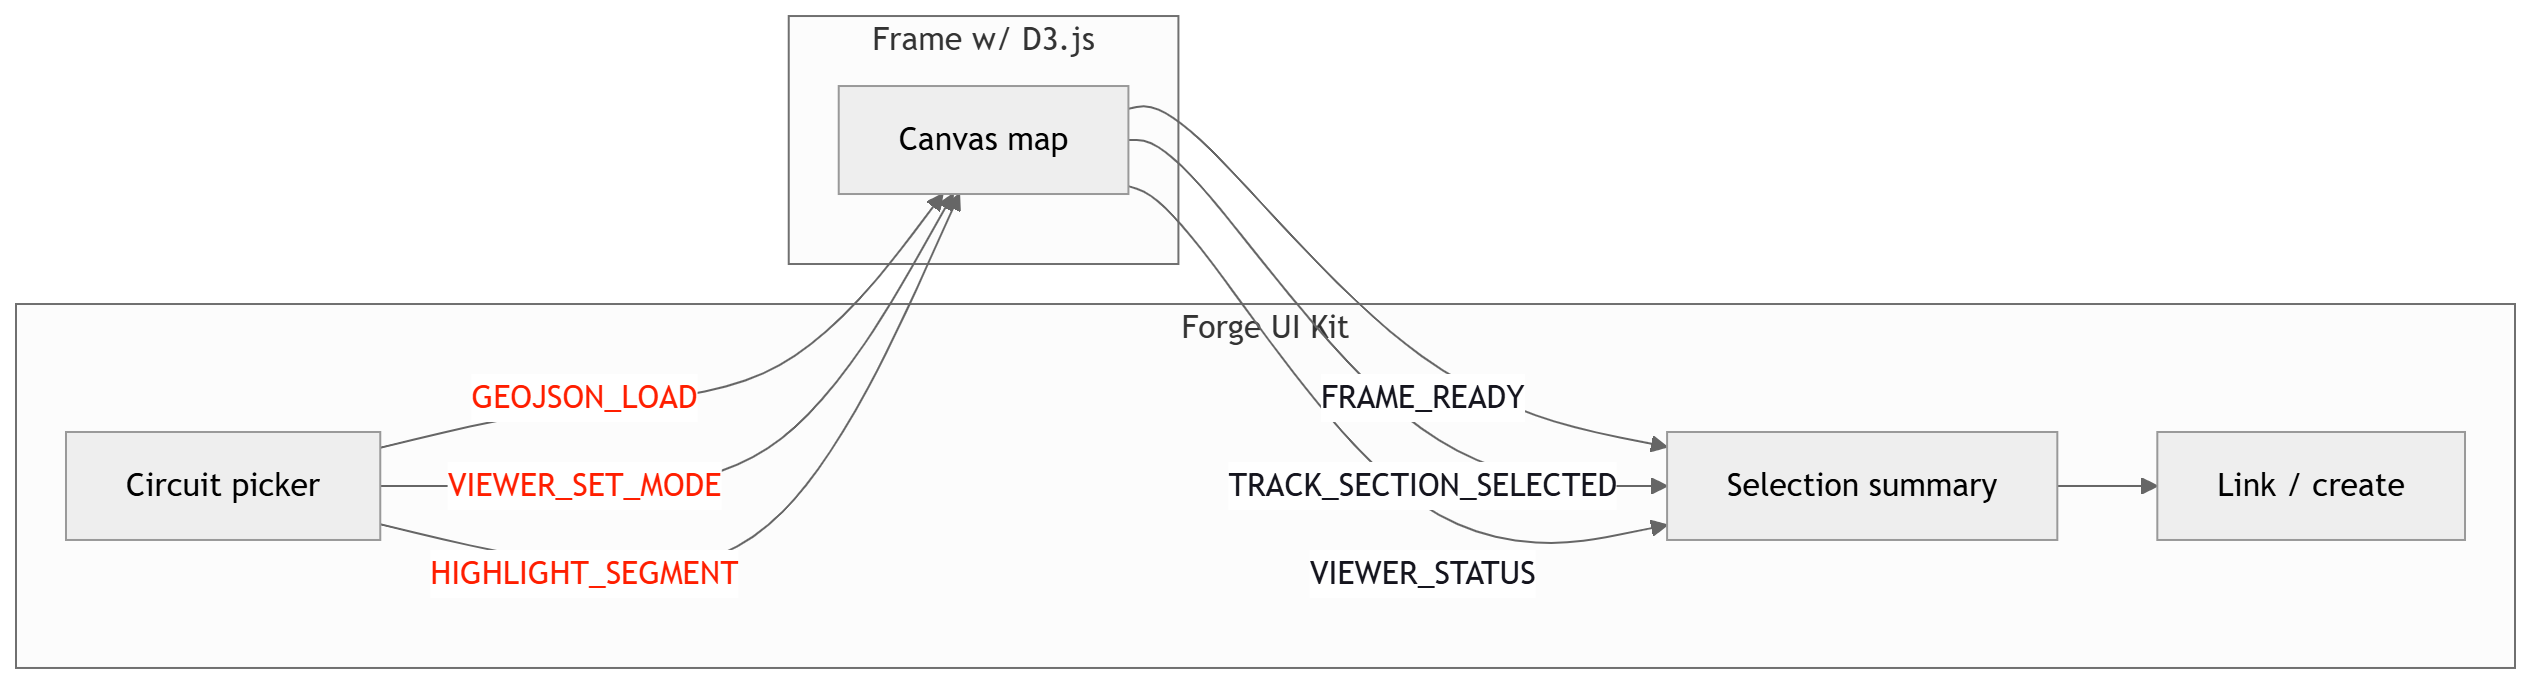
Both directions (can) matter...
- UI Kit → Frame — the shell tells the map what to show: load this circuit, pan vs brush mode, highlight a saved segment, reset view. Jira context (issue key, catalog choice, restored links) can become map behaviour.
- Frame → UI Kit — the map tells the shell what happened: ready signal, selection payload (coordinates, metres along track, thumbnail), status text.
Don't Racing Tracks "Deserve" a Map?
Serving maps as a "layer" is certainly possible and Forge has patterns for that, see Forge remote for example. In this case, it violates the **Runs on Atlassian** constraint the solution is working under.
Code supporting these new changes is found at ft-tracklink/releases.
What's Still to Explore
We'll follow-up with a final post exploring the realities for integrating **Track Linker** more deeply with Teamwork Graph for that increased context accuracy in Rovo. That's in the works...

